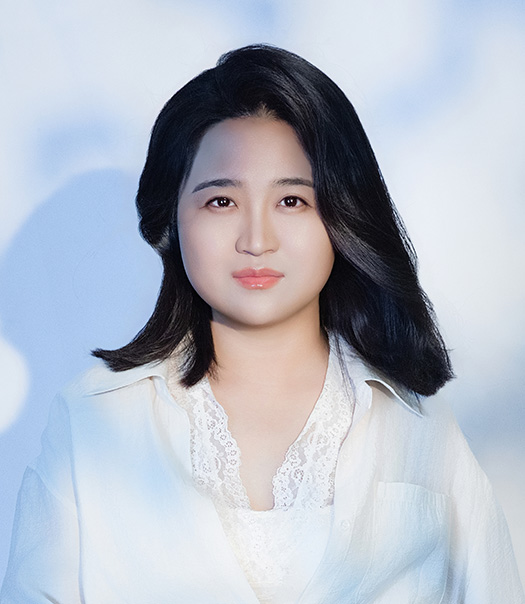
李玮 女 硕导 中国科学院计算技术研究所
电子邮件: liwei2019@ict.ac.cn
通信地址: 北京市海淀区科学院南路6号
邮政编码:100190
研究领域
自动驾驶,自主导航,多传感器融合的导航定位
招生信息
欢迎报考!
自2023年起,本人每年度大致招收1-2名硕士生
招生专业
招生方向
教育背景
工作经历
2021年9月-今,中科院计算所,副研究员
2019年7月2021年9月,中科院计算所,助理研究员出版信息
近五年主要期刊文章:
[1] Liangshu Qian, Wei Li*, Yu Hu*, LVGS-SLAM: LiDAR-Visual-Supervised Gaussian Splatting SLAM with Dense Depth Rendering for Unstructured Environments, IEEE Robotics and Automation Letters, 2026.
[2] Liangshu Qian, Wei Li*, Yu Hu*, Neural LiDAR Odometry With Feature Association and Reuse for Unstructured Environments, Journal of Field Robotics, 2025.
[3] Andong Yang; Wei Li*; Yu Hu*, Speed Planning Based on Terrain-Aware Constraint Reinforcement Learning in Rugged Environments, IEEE Robotics and Automation Letters, 2024.
[4] Yifan Gao; Wei Li*; Yu Hu*, Trajectory Planning for Autonomous Driving Featuring Time-Varying Road Curvature and Adhesion Constraints[J]. IEEE Transactions on Intelligent Transportation Systems, 2024.
近五年主要会议文章:
[1] Fuqiang Jiang, Wei Li*, Tianyao Zhao, Yu Hu, SGC-Lane: Monocular 3D Lane Detection with Standard-Definition Map Guidance and Lane Completion, European Conference on Computer Vision (ECCV), 2026.
[2] Haoming Xu, Wei Li*, Yu Hu, PriorMaskMap: Robust Online Vectorized Map Construction with Biased Priors, European Conference on Computer Vision (ECCV), 2026.
[3] Qingyuan Hu, Wei Li*, Xuebin Meng, Yu Hu*, Monocular Visual Odometry via Diffusion-Based Joint Learning of Optical Flow and Depth, 2026 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2026.
[4] Haoyu Xi, Wei Li*, Yu Hu*, Multimodal Fusion-Guided Diffusion Policy for Motion Planning in Rugged and Obstacle-Dense Environments, 2026 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2026.
[5] Xuebin Meng, Wei Li*, Yu Hu, Yinhe Han, CA2Point: Learning Keypoint Detection and Description with Context Aggregation and Cross Augmentation, 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025.
[6] Aochun Xu, Andong Yang, Wei Li*, Yu Hu*, Vibration-Aware Trajectory Optimization for Mobile Robots in Wild Environments via Physics-Informed Neural Network, 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025.
[7] Guodong Han, Wei Li*, Yu Hu*, Adaptive Sliding Window Optimization for Multi-Modal LiDAR Inertial Odometry and Mapping, 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), IEEE, 2025.
[8] Haoming Xu, Yiyang Xiao, Wei Li*, Yu Hu, Generating Synthetic Deviation Maps for Prior-Enhanced Vectorized HD Map Construction, 2025 IEEE Intelligent Vehicles Symposium (IV). IEEE, 2025.
[9 ]Andong Yang; Wei Li*; Yu Hu*, F3DMP: Foresighted 3D Motion Planning of Mobile Robots in Wild Environments, 2024 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2024.
[10] Andong Yang; Wei Li*; Yu Hu*, SCOML: Trajectory Planning Based on Self-Correcting Meta-Reinforcement Learning in Hybrid Terrain for Mobile Robot, 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). IEEE, 2024.
[11] Haoyu Xi; Wei Li*; Fangzhou Zhao; Liang Chen; Yu Hu*, A Safe and Efficient Timed-Elastic-Band Planner for Unstructured Environments, 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). IEEE, 2024.
[12] Wensong Chen, Wei Li*, Andong Yang, Yu Hu*, Active Visual SLAM Based on Hierarchical Reinforcement Learning, 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). IEEE, 2023:7155-7162.
[13] Cheng Ye , Wei Li*, Yu Hu*, A Tightly-Coupled GNSS RTK/INS Positioning Algorithm Based on Adaptive Lag Smoother. The 2023 IEEE Intelligent Vehicles Symposium (IV 2023). 2023
[14] Andong Yang, Wei Li*, Yu Hu*, SMS-MPC: Adversarial Learning-based Simultaneous Prediction Control with Single Model for Mobile Robots, in IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022.
[15] Jingyu Niu, Yu Hu*, Wei Li, Guangyan Huang, Yinhe Han, Xiaowei Li, Closing the Dynamics Gap via Adversarial and Reinforcement Learning for High-Speed Racing, in IEEE International Joint Conference on Neural Networks (IJCNN), oral (Candidate of Best Paper Award), 2022.
[16] Wei Li, Yu Hu, Yinhe Han, Xiaowei Li, KFS-LIO: Key-Feature Selection for Lightweight Lidar Inertial Odometry, 2021 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2021: 5042-5048.
科研活动
主要科研项目:
[1] 国家自然科学基金项目(青年基金):“面向深空探测巡视器的多传感器融合导航定位方法研究”,项目负责人;
[2] 北京市自然科学基金项目(重点研究专题项目):“车端在线感知与离线地图的融合增强技术研究”,课题负责人;
[3] 国家重点实验室项目:“非结构化场景中多模态融合的定位建图方法研究”,项目负责人;
[4] ——:“火星表面智能感知规划验证系统”,项目负责人;
[5] 国家重点研发计划:科技创新2030-“新一代人工智能”重大项目“无约束环境下基于多传感器信息融合的协同感知”,子课题“资源受限无人系统的轻量化计算”,项目骨干;
[6] 揭榜挂帅项目:“西部高原无人运输车环境感知、导航定位与路径规划关键技术研究”,项目骨干;
[7] ——:“行星巡视器自主导航与自动驾驶关键技术”,项目骨干;
指导学生
现指导学生
肖熠阳 硕士研究生 085404-计算机技术
姜福强 硕士研究生 081200-计算机科学与技术
赵天垚 硕士研究生 085400-电子信息
徐浩铭 硕士研究生 085410-人工智能
李尚鑫 硕士研究生 085410-人工智能
李学坤 硕士研究生 085410-人工智能